SoftGen
EXPERIMENTALGiven a starting shape and a target after inflation, SoftGen searches for chamber layouts and pressures, simulates the result, and exports the geometry.
The aim is direct silicone printing. Material calibration and a printed prototype are still ahead.
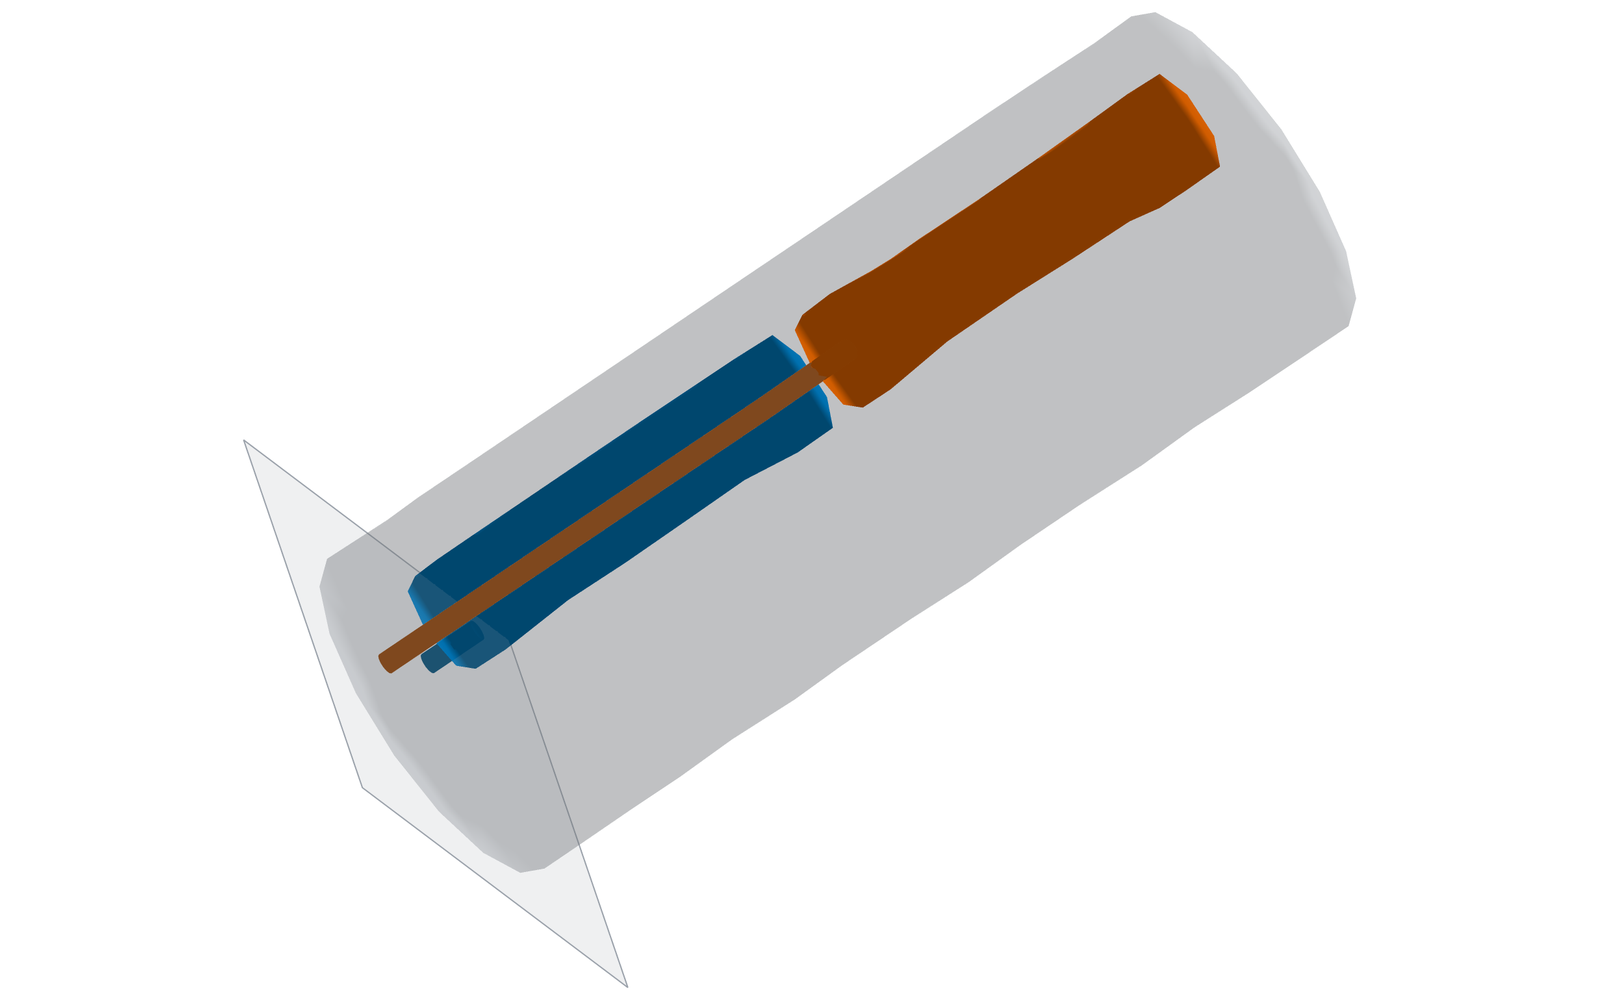
From a starting shape to a target
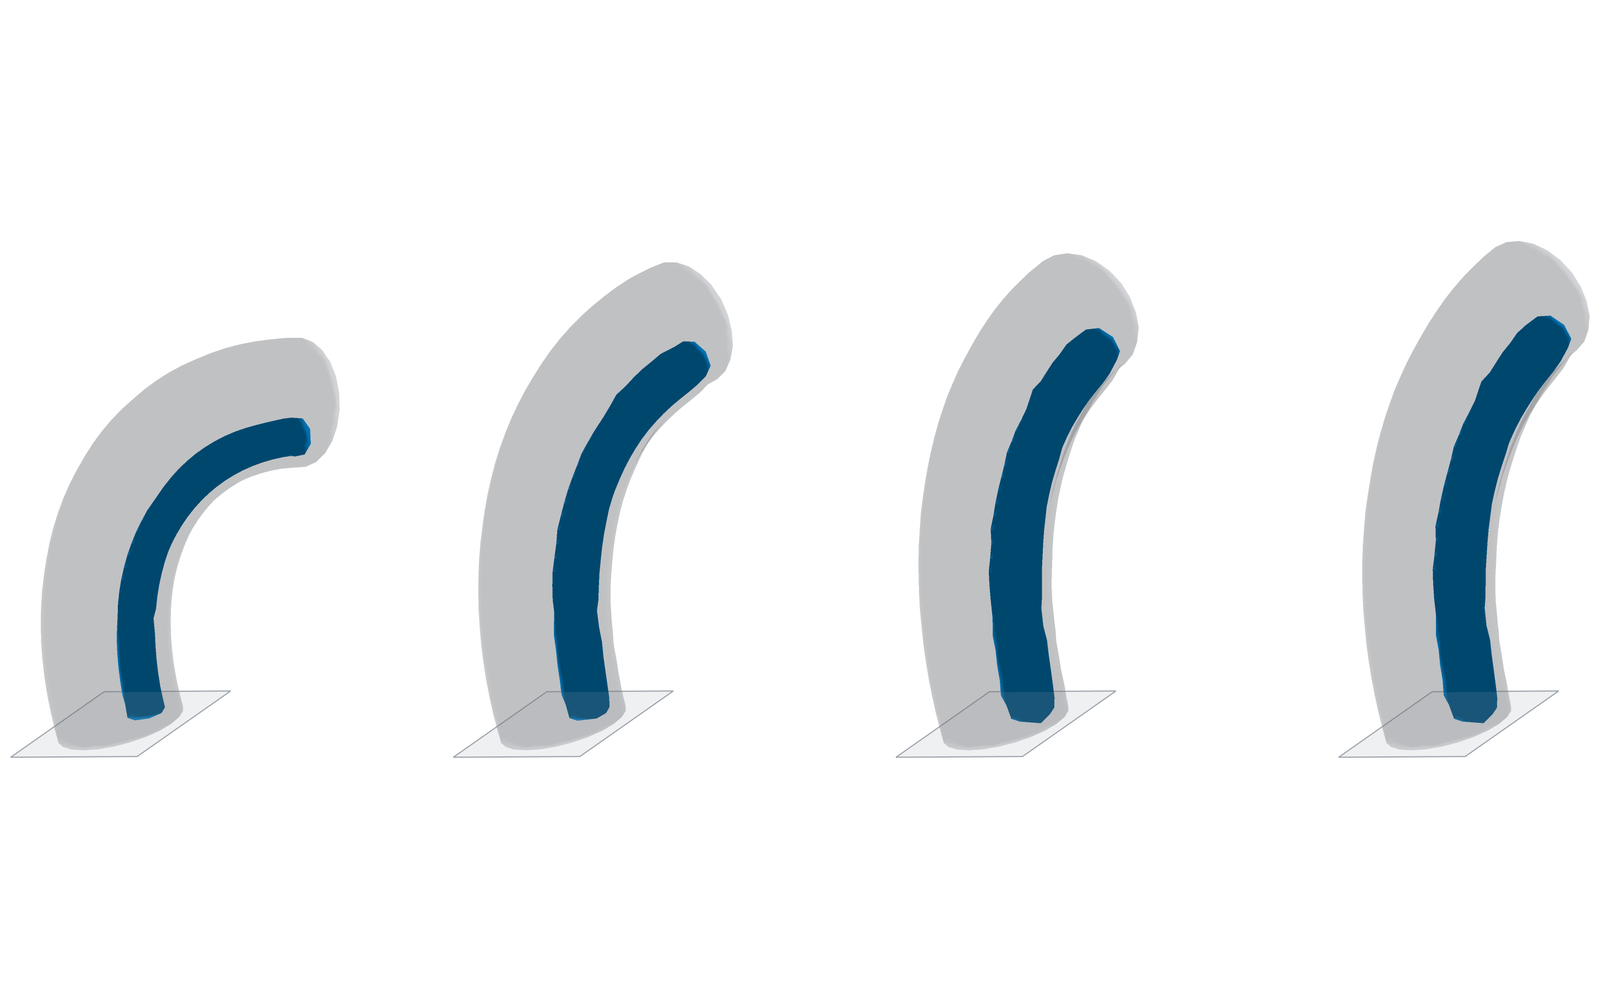
The example below tries to straighten a curved body. It moves toward the target, but does not reach it. The physical model is not yet validated.