Rover and drone
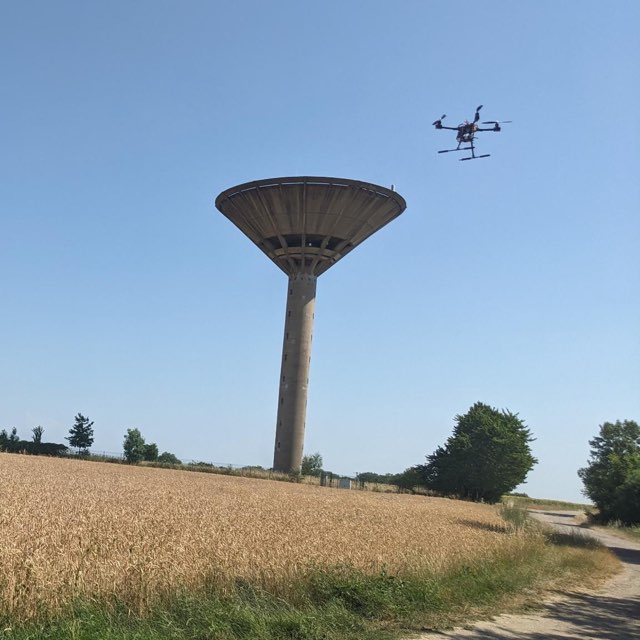
EXPERIMENTALAn 11-inch drone and a four-wheel rover for mapping and data collection. Navigation and localisation are being tested in simulation and on recorded datasets.
The drone has flown with PX4, GPS and optical flow. Rover navigation experiments remain preparatory work before field testing.
The platforms
The rover has ArduSimple RTK GPS, Livox Avia LiDAR, a Raspberry Pi 5 and a hardware-triggered Hikvision camera. Four hoverboard wheel motors run through VESC controllers connected to ROS.
A Livox Mid360 is a hoped-for payload for the drone. Software work includes LIO-SAM and BIEVR-LIO.
Before field testing
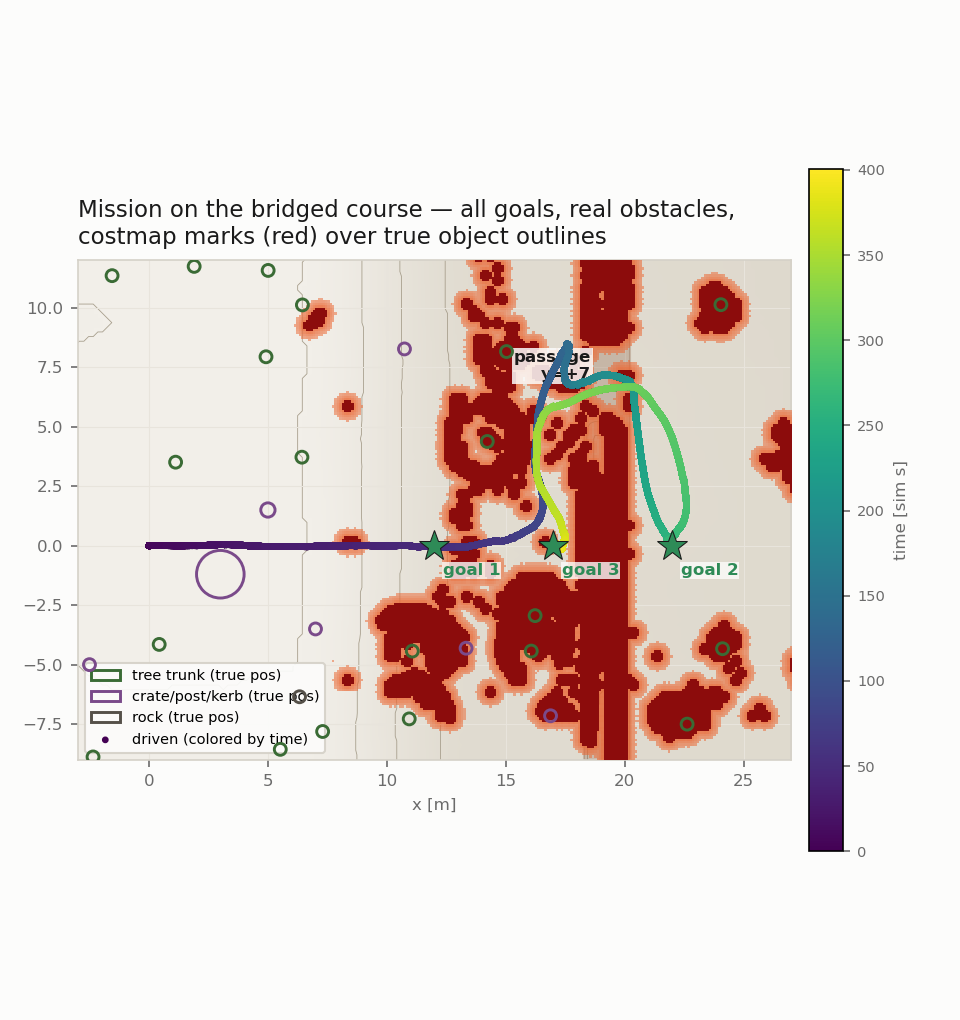
Navigation experiments run in simulation. Odometry and SLAM comparisons use recorded datasets; they do not establish performance in burned forests.